• Home
  • Research
  • Press and Awards
  • Social
  • People
  • Publications
  • Wiki
  • Log In
Skip to content
ModLab - UPenn
  • Home
  • Research
  • Press and Awards
  • Social
  • People
  • Publications
  • Wiki
  • Log In

Category: CHAMPS

Design and Kinematics of CHAMPS: a Configurable, Highly-Articulated, Multi-Purpose Snake

by Haitham AlshehriCHAMPS, Modular RobotsPosted on March 11, 2026August 19, 2026Comments are Disabled

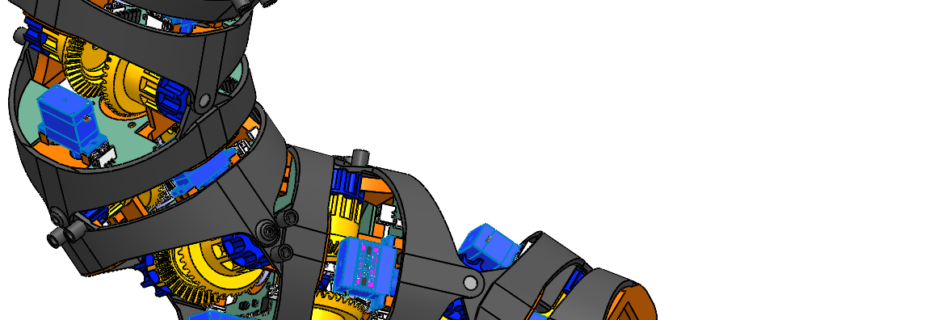
CHAMPS is a configurable, highly articulated modular manipulator driven by a single actuator with selective joint engagement. The design combines shared actuation, embedded locking, and alternating joint geometry to enable scalable hyper-redundant motion.

Copyright © 2026 ModLab - UPenn Inspiro Theme by WPZOOM
Scroll to top